
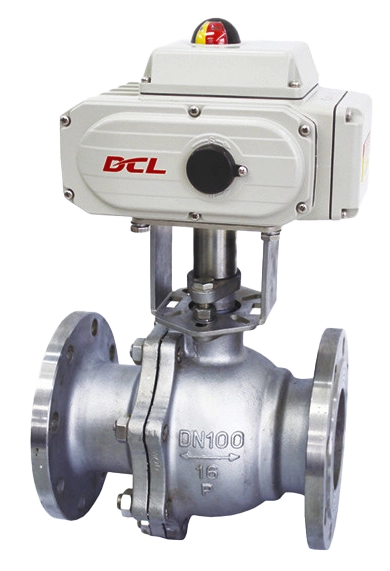
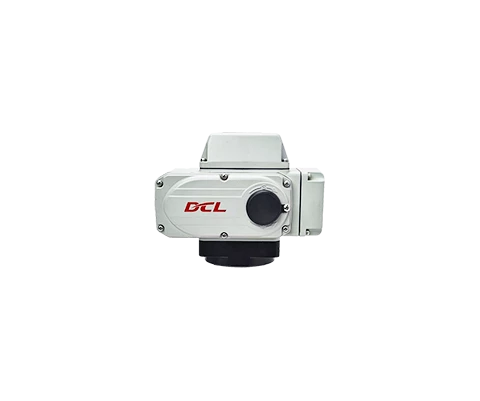
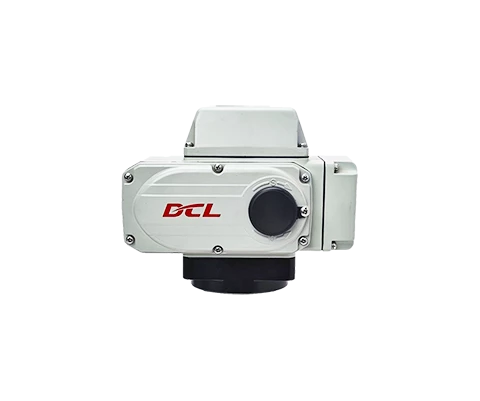
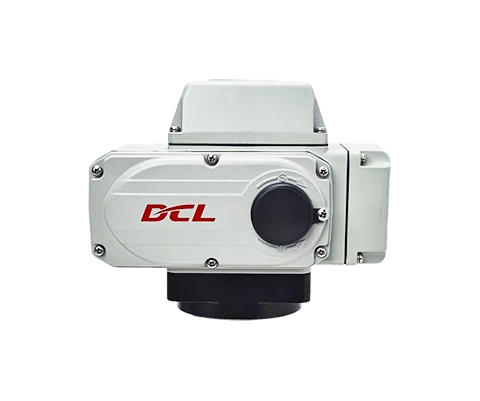
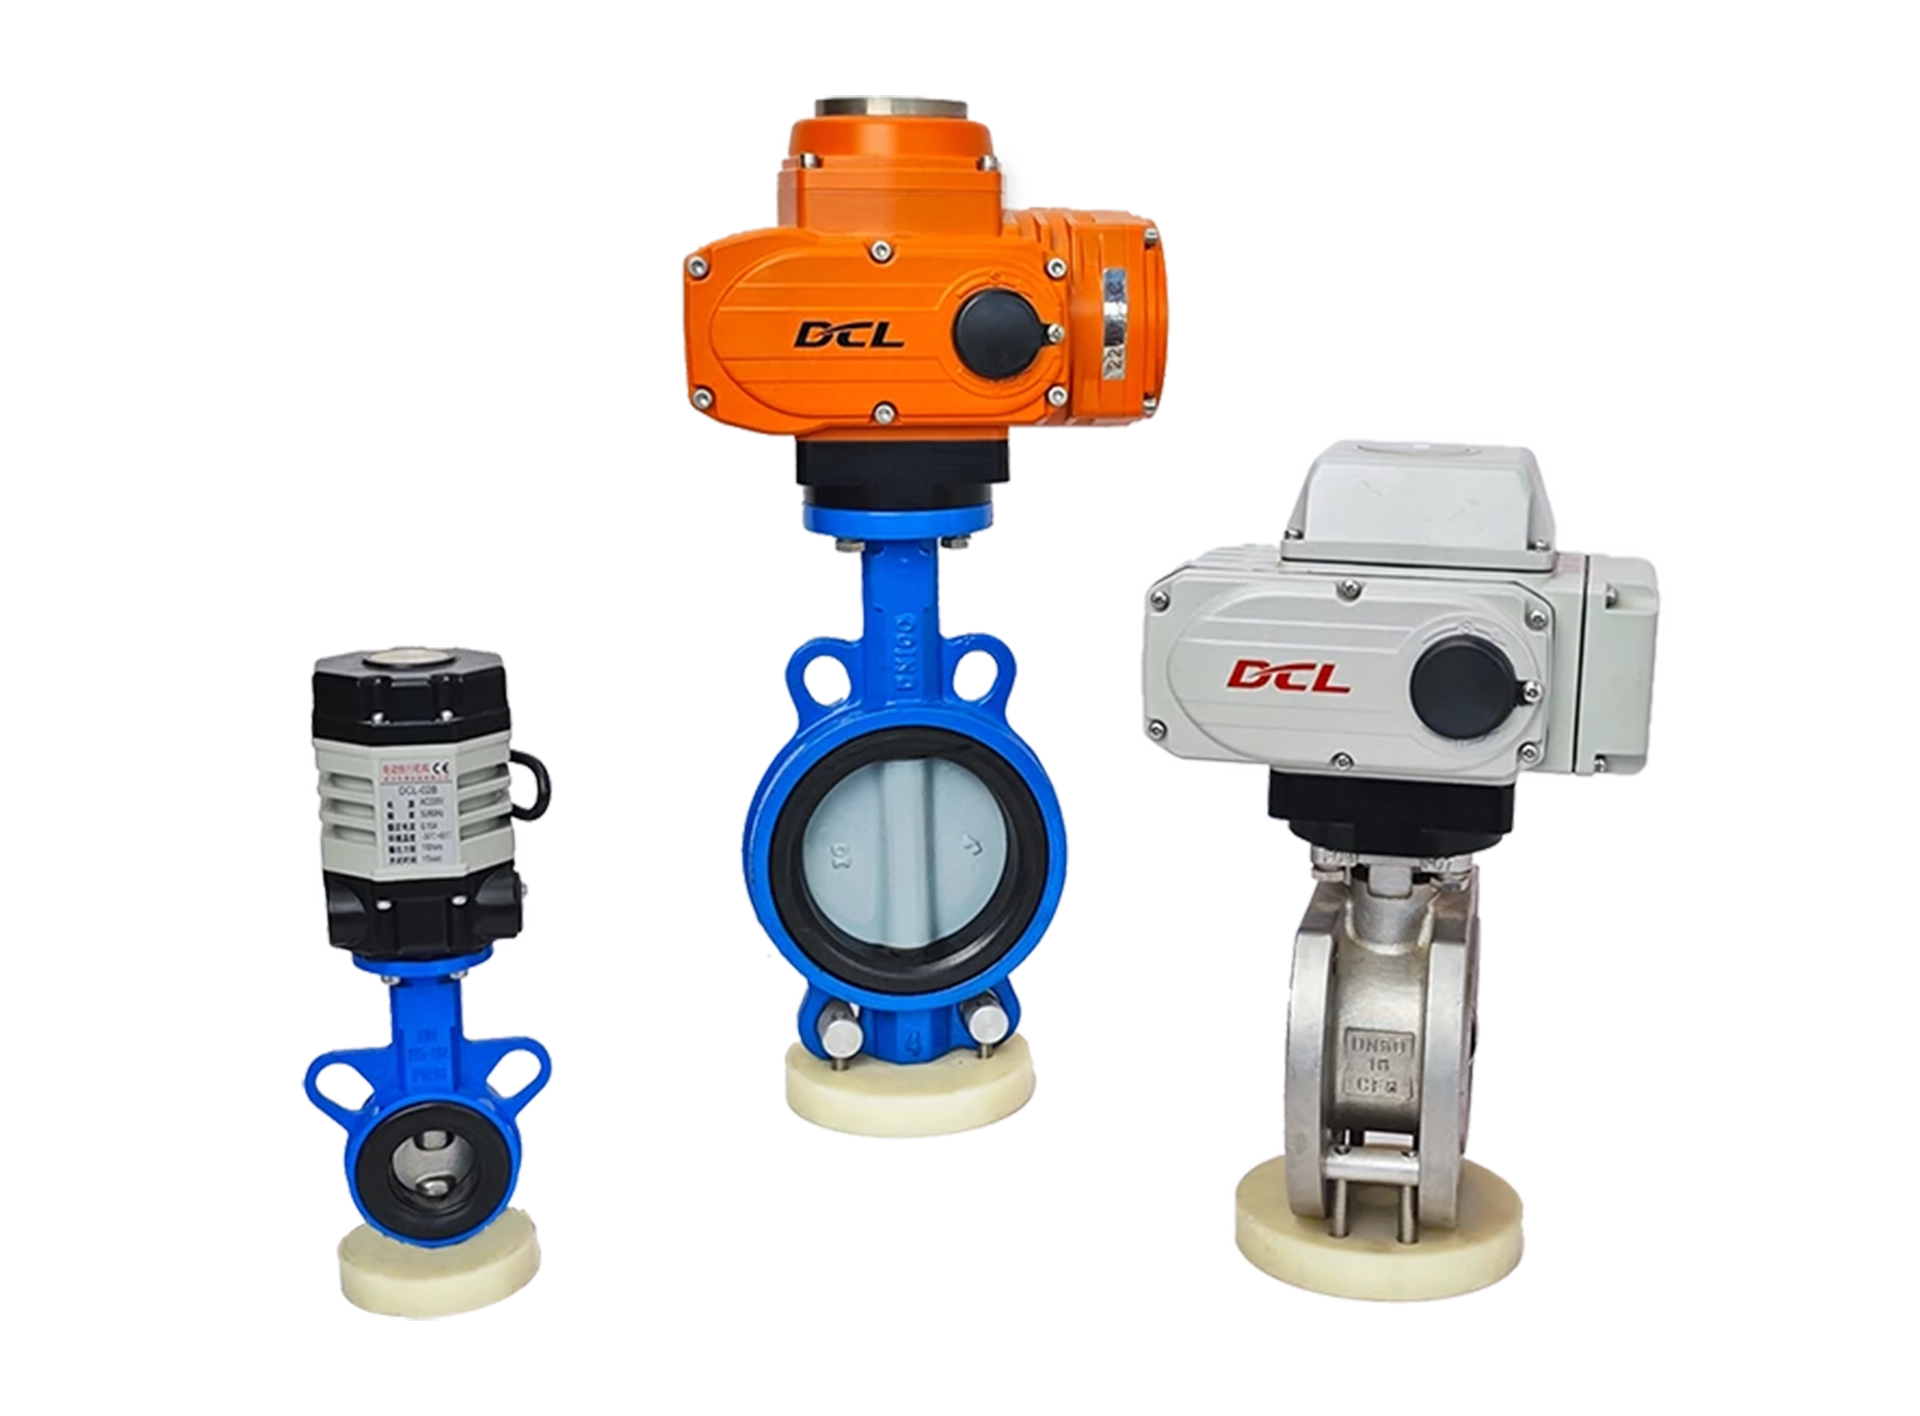
Actuador de giro rápido
Used in scenarios in which valve or damper should be quickly regulated
Directly used outdoors without additional protection
Applicable for part-turn Valve
IP68
Movement Direction
Part-turn
Damper
0 - 90° | 0 - 360°
Tiempo de funcionamiento/Par motor
2S~12S
15~1200Nm
Tipo de trabajo
Modulación
Avance lento - Posicionamiento
On - Off
Tensión de alimentación
24 V CC
24 V CA
CA 110V
CA 220V
CA 380V
Input/Output Signal
4~20mA
0~10V
IO Interface
Operational with fieldbus
Modbus-RTU
Modbus-ASCII
CAN
Ethernet
Opciones adicionales
Over-torque Protection
Fail Safe Return
Deshumidificación
Diagnosis
Tipo de trabajo
Modulación
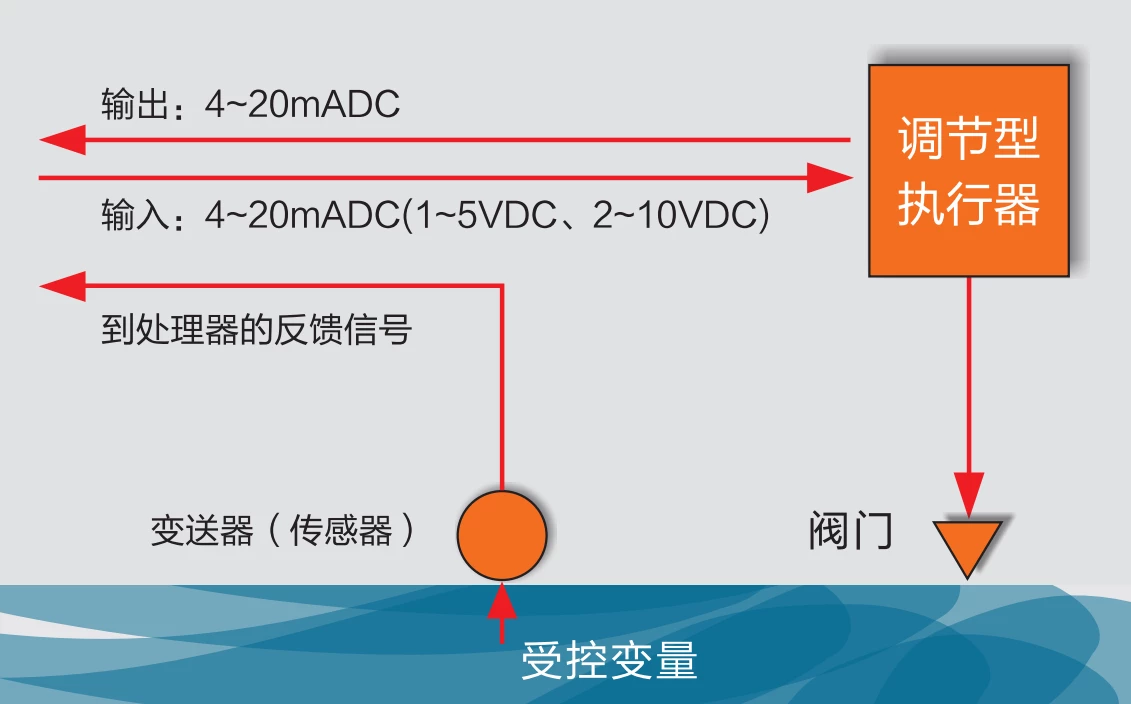
The actuator read the target position value from control system through 4-20mA, 2-10V or field bus such as modbus, ethernet and etc.
Then actuator drive the valve to the target position with interior control algorithm.
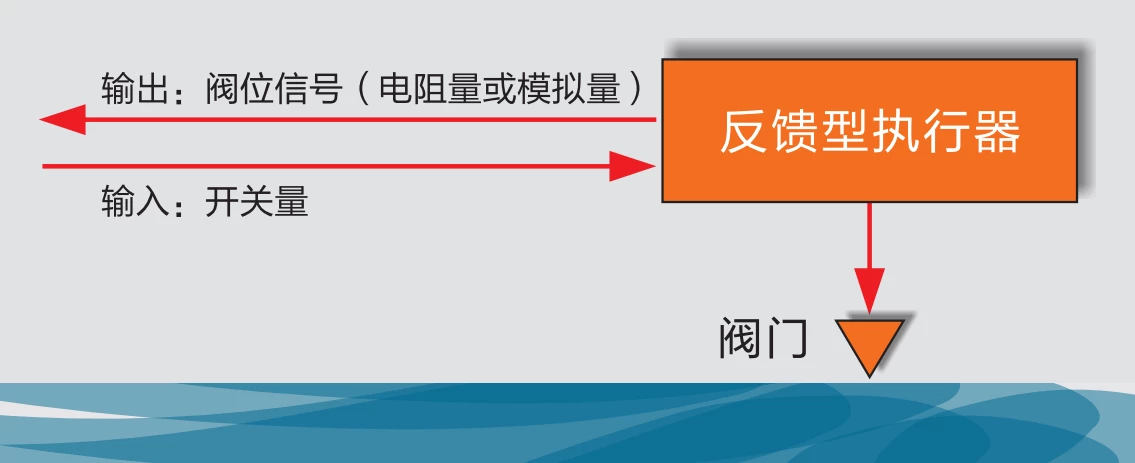
The actuator will always output the real-time valve position through 4-20mA, 2-10V or field bus.
Operated in type of duty S4, the actuator can starts 1200 times per hour.
On - Off
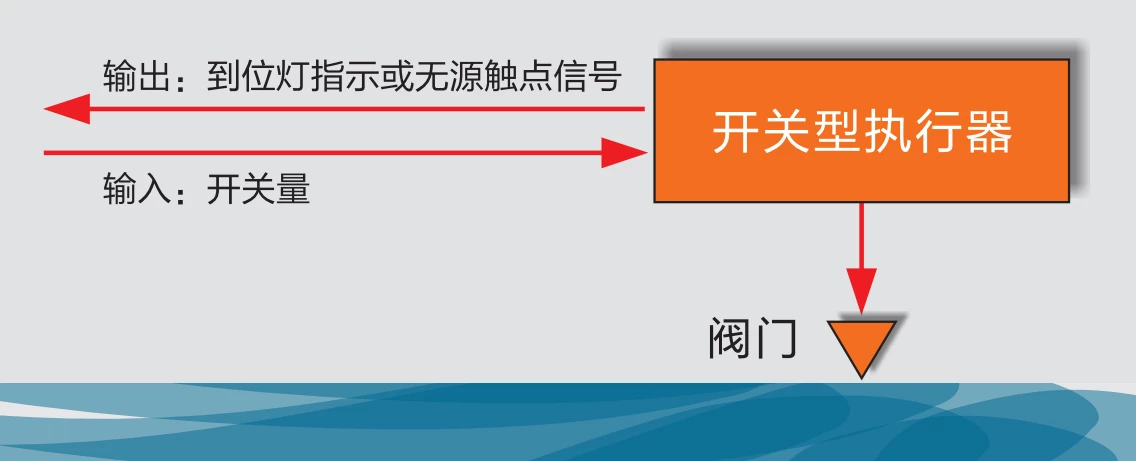
The actuator read the open or close requirement from control system through IO interface such as passive signal or 24VDC/220VAC active signal.
Then actuator drive the valve to the end-position of OPEN or CLOSE as input signal required.
The actuator will output a feedback signal of OPEN or CLOSE when end-position been reached.
Operated in type of duty S2, the actuator can drive valve continuously for 15 minutes.
Avance lento - Posicionamiento
The actuator read the inching OPEN or CLOSE signal from control system through IO interface inputted with 24VDC/220VAC active signal.
Then actuator drive the valve with a stepping way specified by the input inching signal.
The actuator will always output the real-time valve position as a potentiometer resistance value or 4-20mA/2-10V value.
Operated in type of duty S2, the actuator can drive valve continuously for 15 minutes.
Features
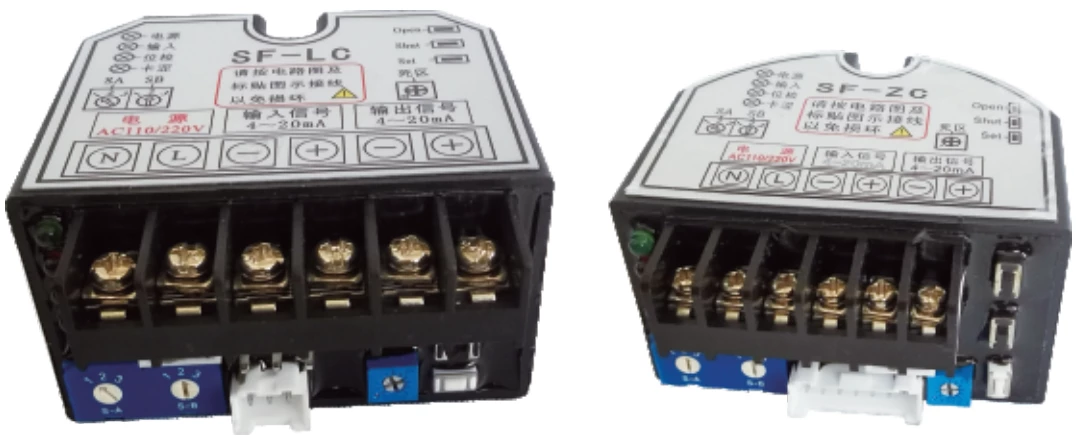
Fully Capsulated Control Unit
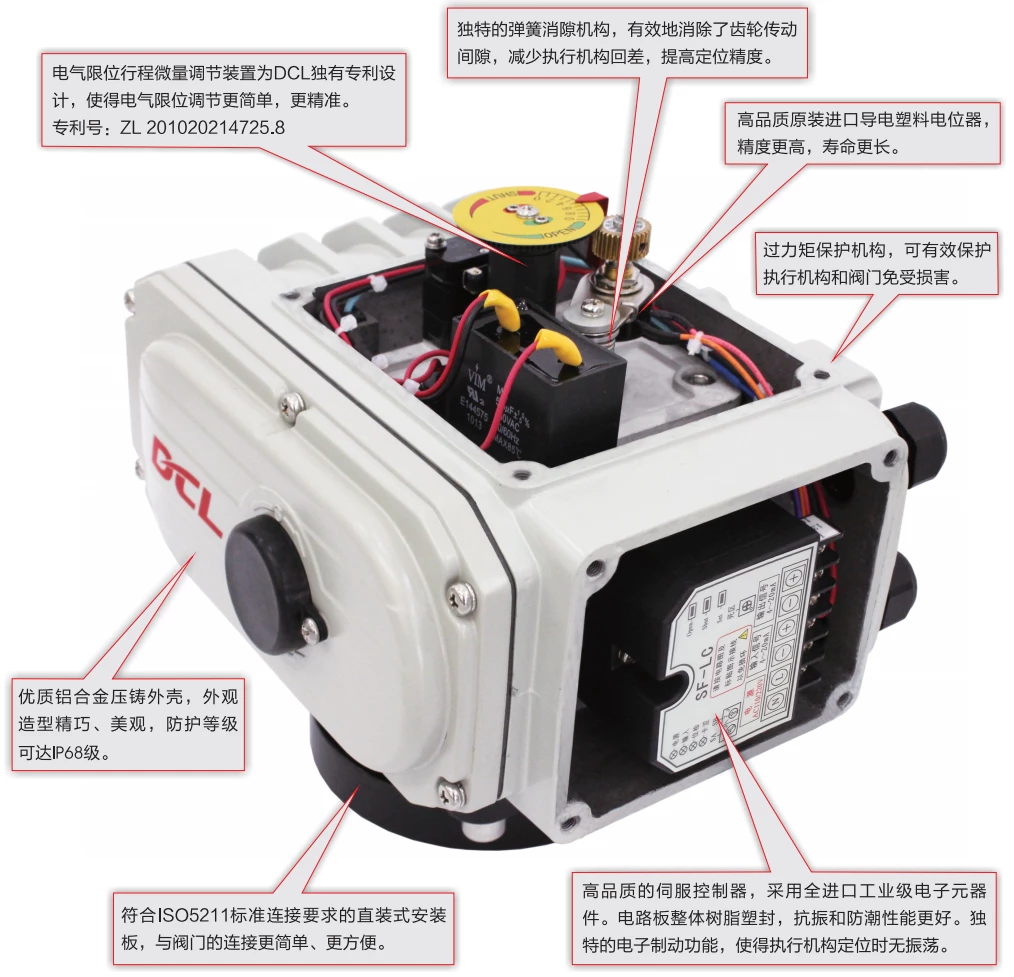
The control unit is fully encapsulated with polyurethane. This greatly enhanced proof performance against moisture, condensation, salt and vibration. So it is applicable in harsh environments such as high humidity, dust, strong temperature changing, vibration, etc.
With 6kV EFT and surge protection circuit, the stable control to the valve can be ensured even in worst electromagnetic environment.
By self-adjustment algorithm, the actuator can keep the precision against different loads conditions and mechanical wear by time.
Easy-to-use Limit Switch
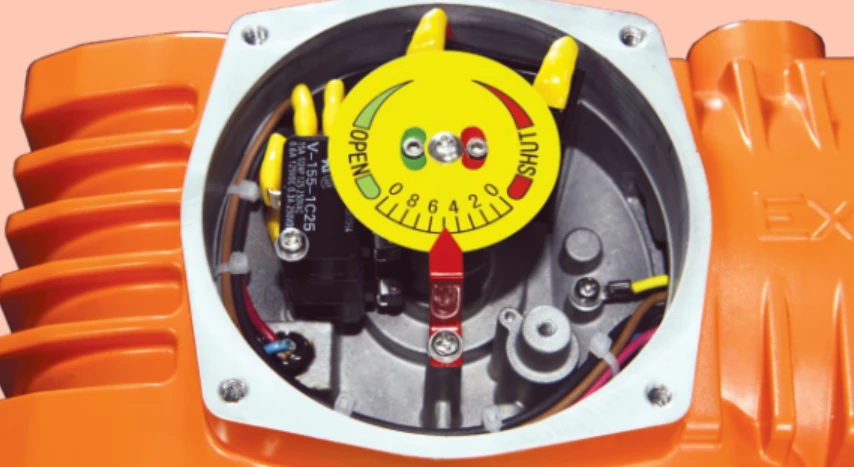
With DCL’s patented limit switch design, the actuator’s end position of open and close can be easily configured only with a hexagonal wrench.
In the meantime the micro adjustment feature of limit switch can improve the precision when setting the end-position.
Patent No. ZL 201020214725.8
Motor with Over Temperature Protection
DCL specially design the motor to fit the actuator requirement so that the motor in DCL actuator can supply a high start torque while maintain a high efficiency in the start phase to make the temperature rise as low as possible. In the meantime the motor have a small moment of inertia to make sure the high precision in modulation.
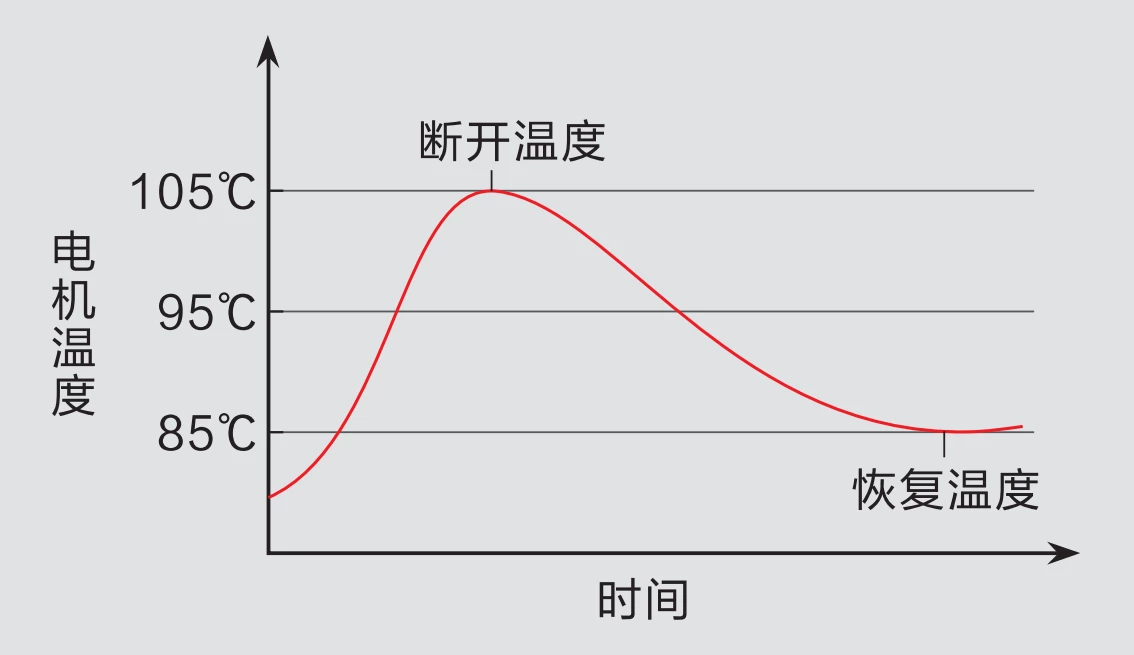
There is an over temperature protection device mounted in the motor which will cut the power supply when the motor temperature goes higher then the limited temperature(105℃/85℃ can be selected up on the application scenario) and connect the power supply again when the temperature recovered below the Normal temperature.
Dual Position Limiter
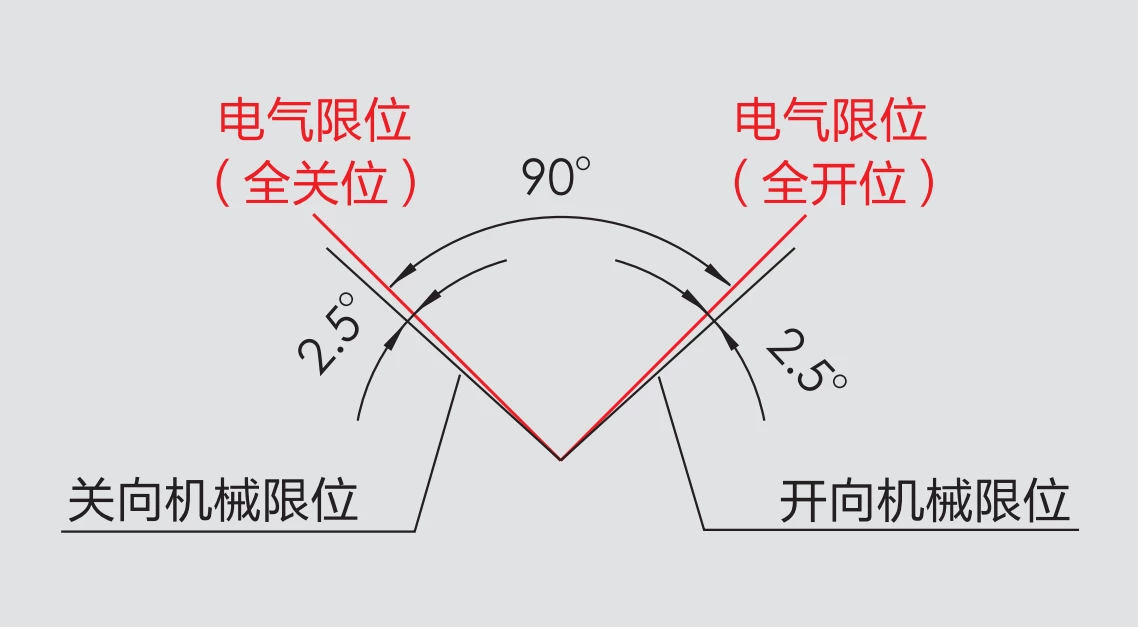
There are 2 position limit devices to protect valve from damage by operation over swing angle.
Electric limit switch are mounted on the both end-position of OPEN and CLOSE. So the power supply to motor will be cut off to stop driving the valve after limited end-position was reached.
Also there are 2 mechanical limiters mounted on the output shaft to protect the valve from swing over stroke range. The mechanical limiter will not take effect in normal operation cause the electric limit switch is ahead of the mechanical limiter and will be triggered before the output shaft can reach the mechanical limited positon.
Opciones adicionales
Over-torque Protection
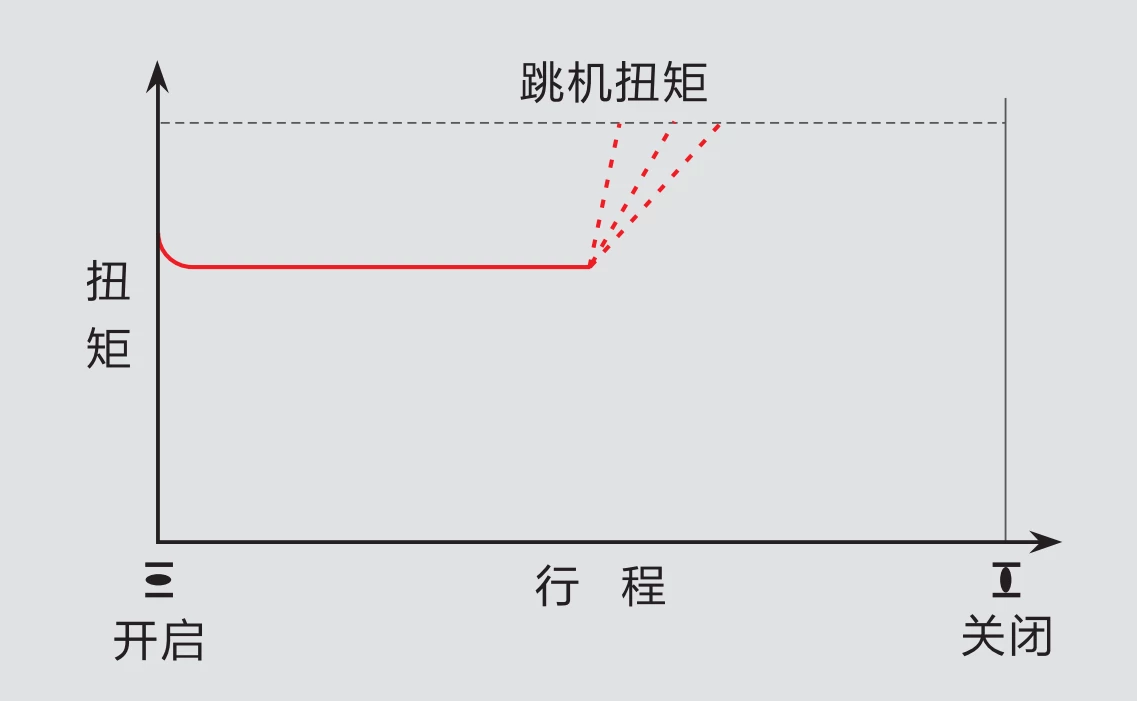
When the valve is stuck by some reason such as solid impurities in the liquid or malfunction on some mechanical parts, the torque on output shaft of actuator will increased sharply beyond the limit torque value when driving the valve, then the actuator would trig an over torque protection to stop driving the valve in order to protect the valve from damage.
Dehumidifying
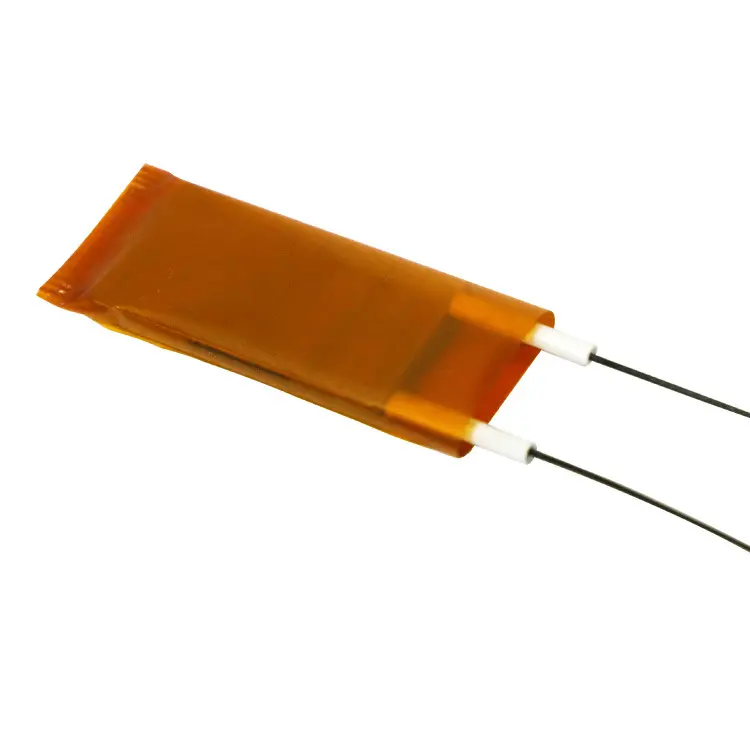
You can choose a dehumidifying option on DCL actuator. Then a electric PTC heater will be mounted in the actuator to reduce humidity to protect circuit from malfunction in high range of temperature changing circumstance due to condensation.
The PTC heater will be in working mode as long as power is supplied to actuator.
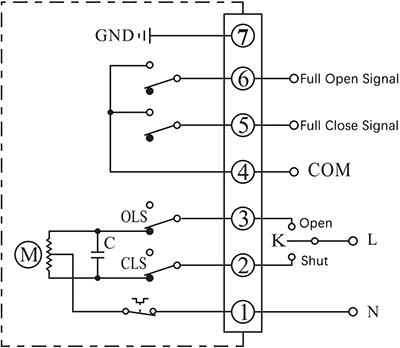
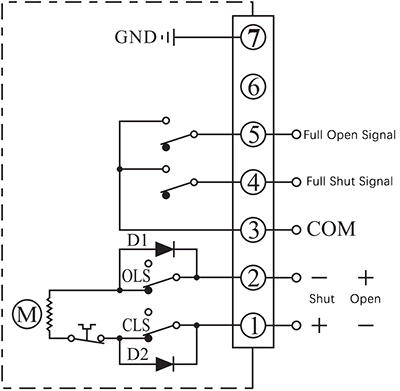
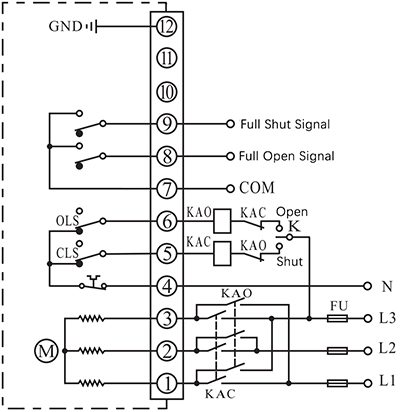
Circuit Diagram
Modulación
E - Modulación con una unidad de control
- Entrada: 4~20 mA / 0~10 V
- Salida: 4~20 mA / 0~10 V
- Bus de campo: Modbus / CAN
- IIoT: DTU WIFI/LoRA/4G
Avances y posicionamiento
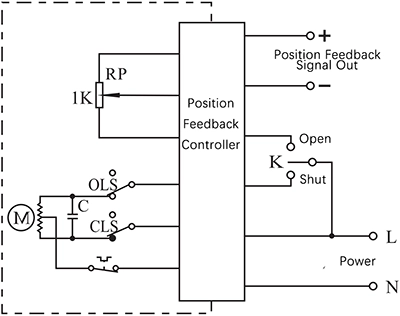
F - Con una unidad de posicionamiento
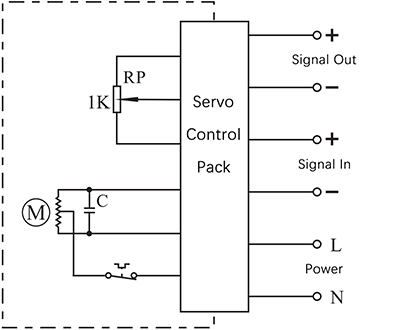
- Controlar el actuador para abrir o cerrar con K
- The real-time valve position will be send out as a 4-20mA signal
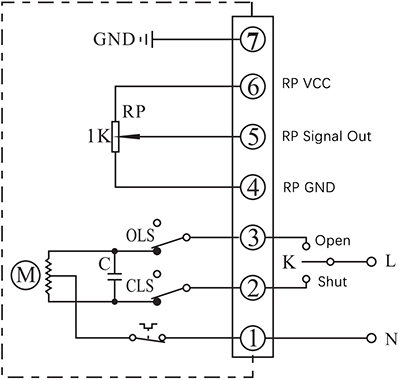
C - Con un potenciómetro de 1 kΩ/500 Ω
- Controlar el actuador para abrir o cerrar con K
- La posición de la válvula en tiempo real se enviará como un valor de resistencia del potenciómetro.
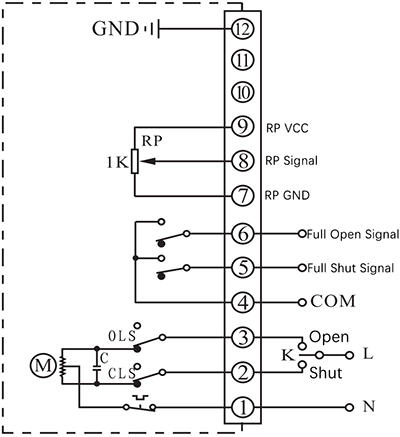
D - Con un potenciómetro y retroalimentación de posición final.
- Controlar el actuador para abrir o cerrar con K
- La posición de la válvula en tiempo real se enviará como un valor de resistencia del potenciómetro.
- El terminal de salida de la posición final APERTURA/CIERRE enviará el evento como una señal pasiva cuando se alcance la posición final.
ENCENDIDO - APAGADO
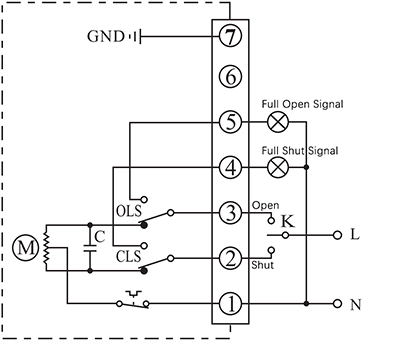
A - Con 2 salidas de señal de posición final activas
- Controlar el actuador para abrir o cerrar con K
- El terminal de salida de la posición final APERTURA/CIERRE enviará el evento como una señal activa de 220 VCA cuando se alcance la posición final.
B - Con 2 interruptores de posición final pasivos
- Controlar el actuador para abrir o cerrar con K
- El terminal de salida de la posición final APERTURA/CIERRE enviará el evento como una señal pasiva cuando se alcance la posición final.
G - Motor de CC con 2 interruptores de posición final.
- Controla el actuador para que se abra o se cierre mediante la dirección de la alimentación eléctrica entre los terminales 1 y 2.
- El terminal de salida de la posición final APERTURA/CIERRE enviará el evento como una señal pasiva cuando se alcance la posición final.
Motor H - trifásico de 380 VCA con 2 interruptores de posición final.
- Controlar el actuador para abrirlo o cerrarlo mediante un inversor externo para cambiar la fase de la alimentación eléctrica.
- El terminal de salida de la posición final APERTURA/CIERRE enviará el evento como una señal pasiva cuando se alcance la posición final.
Nota:
- El circuito dentro del recuadro punteado es el circuito interno del actuador. El circuito exterior muestra la conexión eléctrica para el funcionamiento del actuador.
- Si tiene otros requisitos específicos sobre la conexión del circuito, no dude en ponerse en contacto con nuestro servicio de asistencia técnica.
Basic Parameters
| Model | Ángulo de oscilación | Tiempo de funcionamiento/Par motor | Duty Type | Tensión de alimentación | Input/Output Signal | Opciones adicionales |
|---|---|---|---|---|---|---|
| DCL-K05 | 0 - 270° | 6s/30Nm Opcional con 2s/15Nm 3s/15Nm 5s/30Nm | ENCENDIDO - APAGADO Modulación Avance lento - Posicionamiento | 24 V CC 24 V CA CA 110V CA 220V CA 380V | 4-20 mA 0-10V IO Interface Optional with field bus Modbus-RTU Modbus-ASCII CAN Ethernet | Over torque protection Fail Safe Return Deshumidificación Autobús de campo |
| DCL-K10 | 0 - 90° | 2s/25Nm Opcional con 4s/50Nm 8s/80Nm | ENCENDIDO - APAGADO Modulación Avance lento - Posicionamiento | 24 V CC 24 V CA CA 110V CA 220V CA 380V | 4-20 mA 0-10V IO Interface Optional with field bus Modbus-RTU Modbus-ASCII CAN Ethernet | Over torque protection Fail Safe Return Deshumidificación Autobús de campo |
| DCL-K20 | 0 - 90° | 8s/200Nm Opcional con 2s/50Nm 4s/100Nm | ENCENDIDO - APAGADO Modulación Avance lento - Posicionamiento | 24 V CC 24 V CA CA 110V CA 220V CA 380V | 4-20 mA 0-10V IO Interface Optional with field bus Modbus-RTU Modbus-ASCII CAN Ethernet | Over torque protection Fail Safe Return Deshumidificación Autobús de campo |
| DCL-K40 | 0 - 90° | 8s/330Nm Opcional con 2s/80Nm 4s/160Nm | ENCENDIDO - APAGADO Modulación Avance lento - Posicionamiento | 24 V CC 24 V CA CA 110V CA 220V CA 380V | 4-20 mA 0-10V IO Interface Optional with field bus Modbus-RTU Modbus-ASCII CAN Ethernet | Over torque protection Fail Safe Return Deshumidificación Autobús de campo |
| DCL-K100 | 0 - 90° | 12 s/1200 Nm Opcional con 4s/500Nm 8s/800Nm | ENCENDIDO - APAGADO Modulación Avance lento - Posicionamiento | 24 V CC 24 V CA CA 110V CA 220V CA 380V | 4-20 mA 0-10V IO Interface Optional with field bus Modbus-RTU Modbus-ASCII CAN Ethernet | Over torque protection Fail Safe Return Deshumidificación Autobús de campo |
Recommend actuator to drive a butterfly valve
Recommend actuator to drive a Ball valve
Recommend actuator to drive a ventilation valve
Recommend valve to be driven by DCL weather-proof actuator
Note: The recommendations in the above table is for reference only in common application scenario, the specific torque needed to drive the valve is depended up on the real application case.
It is recommended to choose an actuator with 1.1-1.3 times of torque than the value that was finalized after evaluation of torque requirement of valve and liquid pressure in the pipe. This would improve the robust performance in most worst case.
Choose an actuator based on different torque
6s/30Nm
———————–
Opcional con
2s/15Nm
3s/15Nm
5s/30Nm
2s/25Nm
———————–
Opcional con
4s/50Nm
8s/80Nm
8s/200Nm
———————–
Opcional con
2s/50Nm
4s/100Nm
8s/330Nm
———————–
Opcional con
2s/80Nm
4s/160Nm
12 s/1200 Nm
———————–
Opcional con
4s/500Nm
8s/800Nm